📄 仓库 README
在 GitHub 查看 ↗


Newton
Newton is a GPU-accelerated physics simulation engine built upon NVIDIA Warp, specifically targeting roboticists and simulation researchers.
Newton extends and generalizes Warp's (deprecated) warp.sim module, and integrates
MuJoCo Warp as its primary backend. Newton emphasizes GPU-based computation, OpenUSD support, differentiability, and user-defined extensibility, facilitating rapid iteration and scalable robotics simulation.
Newton is a Linux Foundation project that is community-built and maintained. Code is licensed under Apache-2.0. Documentation is licensed under CC-BY-4.0. Additional and third-party license texts are available in newton/licenses.
Newton was initiated by Disney Research, Google DeepMind, and NVIDIA.
Requirements
- Python 3.10+ (3.10 support is deprecated; removal planned for Newton 1.9; use 3.11+)
- OS: Linux (x86-64, aarch64), Windows (x86-64), or macOS (CPU only)
- GPU: Fresh installs currently select Warp 1.18, which requires an NVIDIA Turing GPU (compute capability 7.5+) and driver R580+ for CUDA acceleration.
On an R545–R579 driver or an older supported GPU, install with
warp-lang==1.17.0(see the installation guide). No local CUDA Toolkit is required; macOS runs on CPU.
For detailed system requirements, see the installation guide. For tested configurations and Newton's versioning and deprecation policies, see the compatibility guide.
Quickstart
pip install "newton[examples]"
python -m newton.examples
To install from source with uv, see the installation guide.
Community Projects
Explore community solvers, integrations, and applications through the newton-physics topic on GitHub.
To share your own project, add the newton-physics topic to your public repository's About section. See GitHub's guide to repository topics for instructions.
Projects opt in by adding the topic; inclusion does not imply endorsement or support by the Newton maintainers. External solvers and extensions are maintained separately from Newton. Check each project's documentation for maturity, compatibility, and support.
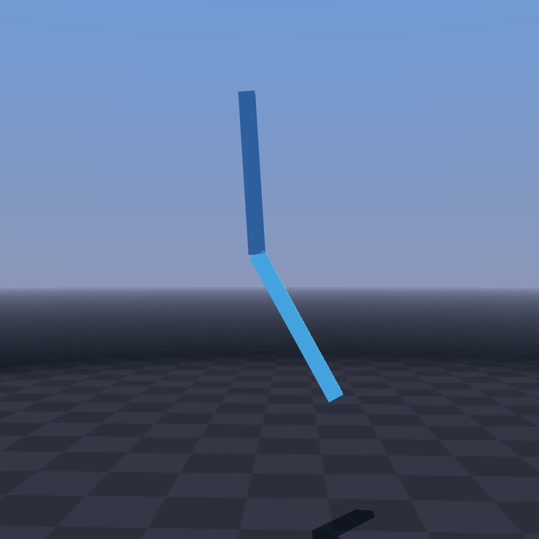
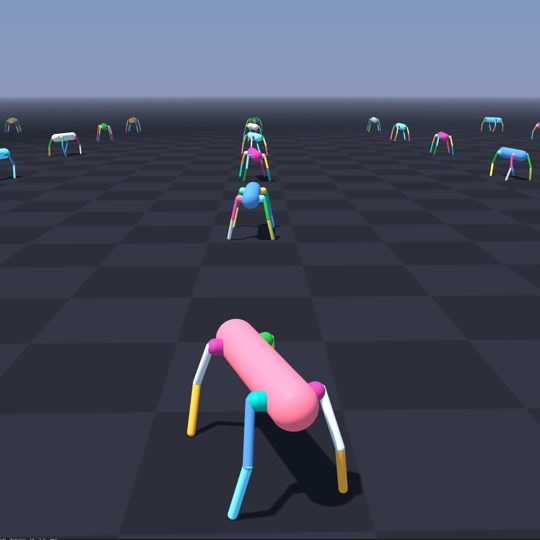
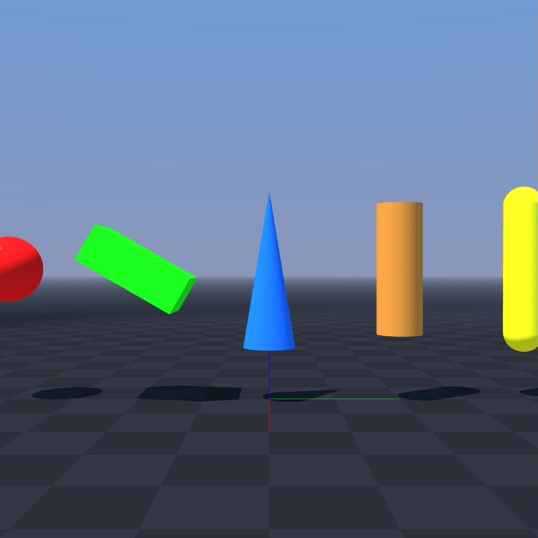
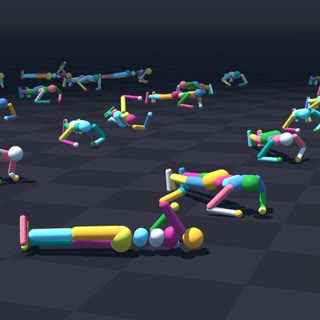
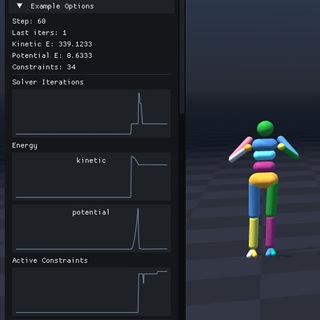
Examples
Before running the examples below, install Newton with the examples extra:
pip install "newton[examples]"
If you run the examples from a source checkout with uv, use
uv run --extra examples -m newton.examples <example_name> instead of the
python -m newton.examples <example_name> commands below.
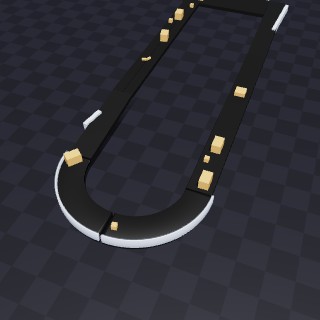
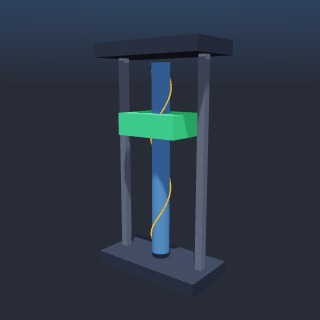
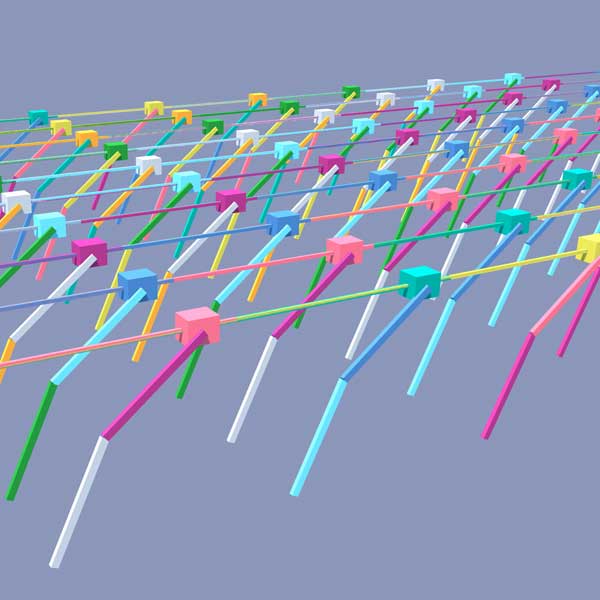
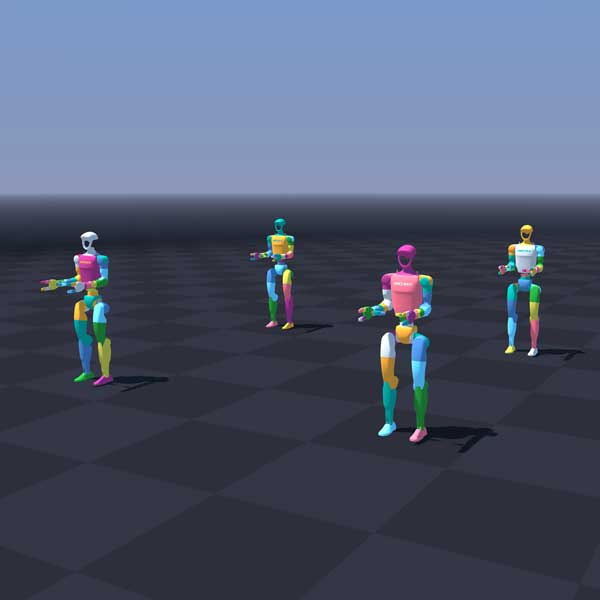
📈 近 7 天 Star 趋势
🏆 排名变化趋势
📋 历史上榜记录
| 日期 | 榜单 | 排名 | 周期新增 | 总 STAR |
|---|